XMas 2025 – 12th of Dec 2025
Thank you to the CPS team for a successful year, which we concluded with a delightful Christmas party at the local restaurant Erlsbacher in Leoben.
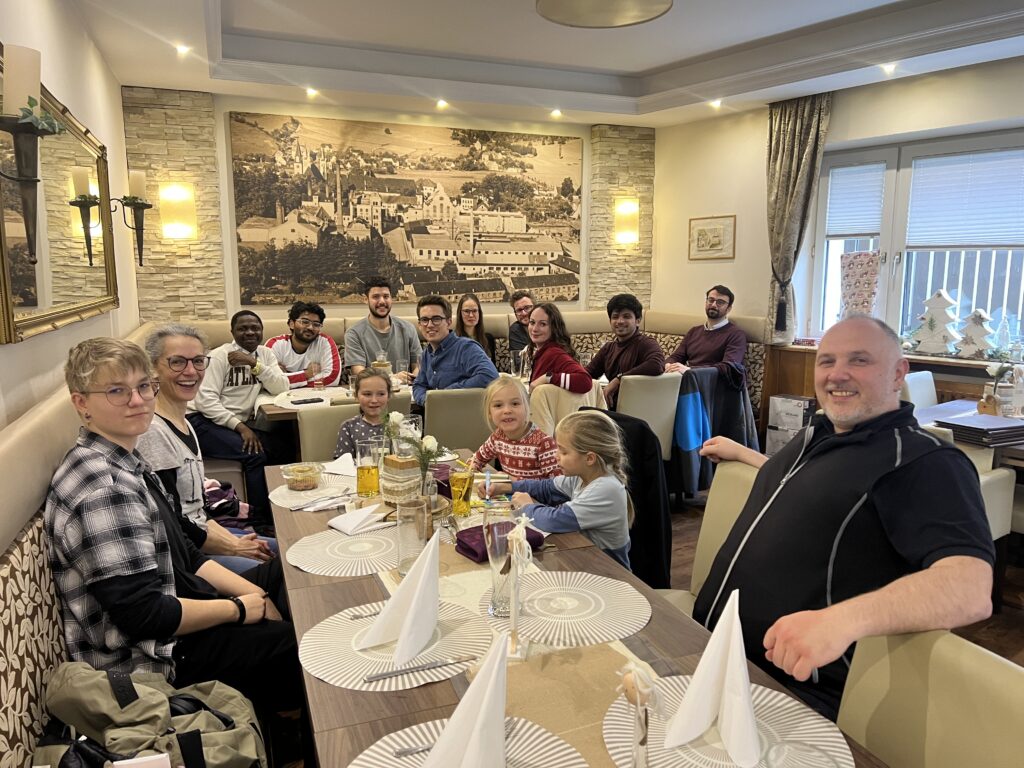
Thank you to the CPS team for a successful year, which we concluded with a delightful Christmas party at the local restaurant Erlsbacher in Leoben.
The Ouster 3D LiDAR is a cutting-edge sensor designed for high-performance mapping and perception in various applications, including autonomous vehicles, robotics, and industrial automation. This LiDAR provides exceptional resolution and range, making it ideal for detailed environmental sensing. Our example usage can be found at: https://linusnep.github.io/EnvoDat/.


https://cps.unileoben.ac.at/wp/EnvoDat-Summary.mp4
Short bio: Katharina Binder joined the CPS team in November 2025 and is responsible for organizational and administrative matters. She holds a diploma from the International Bilingual Business College in Hetzendorf with a focus on marketing. Before that, she completed her secondary education at the Higher Institute for Tourism in Krems, specializing in tourism management. She also studied political science at the University of Vienna.
Katharina Binder
Sekretariat des Lehrstuhls für Cyber-Physical-Systems
Montanuniversität Leoben
Franz-Josef-Straße 18,
8700 Leoben, Austria
Phone: +43 3842 402 – 1901
Email: sandra.binder@unileoben.ac.at
Web: https://cps.unileoben.ac.at
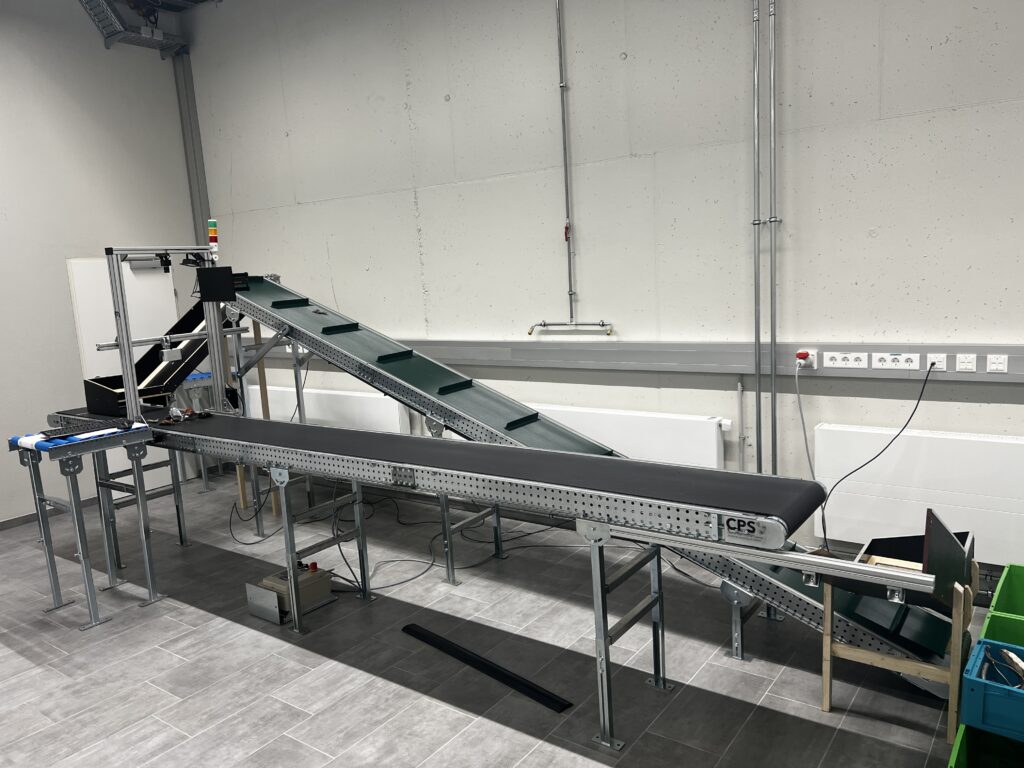
Our conveyer belt system has a dimension of approx. 5 x 3 meters with 40cm belts. It is used to develop autonomous robotic systems for recycling applications.
Supervisor: Christian Rauch;
Univ.-Prof. Dr Elmar Rückert
Start date: April 2025
Theoretical difficulty: mid
Practical difficulty: low
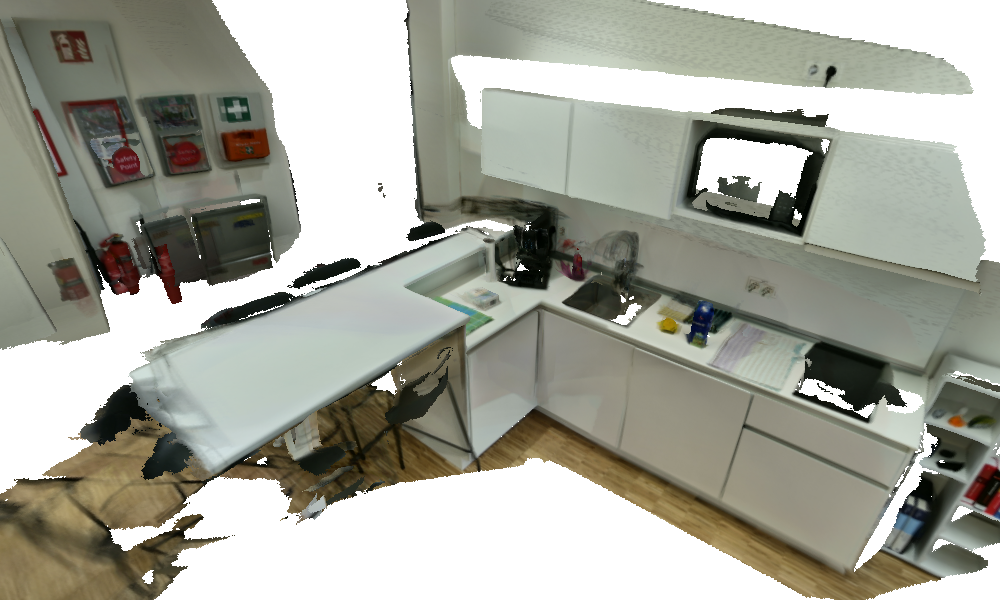
Vision-Language Models (VLMs) are novel methods that can related image information and text via a common embedding space. But these methods, trained on 2D image data, can only operate on the current view point of a camera.
On the other hand, neural rendering techniques, such as NeRF [1] or 3D Gaussian Splatting [2], enable compressing multiple image views into a highly detailed representation, which is useful for novel view synthesis in SLAM approaches.
Related work, such as LERF [3] and LangSplat [4] are combining these two approaches to create a compressed 3D representation of these vision-language embeddings, but are far from real-time capable, and usually do not provide a representation in metric space, making them unsuitable for robotic applications.
To achieve the objectives, the following concrete tasks will be focused on:
[1] Ben Mildenhall, Pratul P. Srinivasan, Matthew Tancik, Jonathan T. Barron, Ravi Ramamoorthi, and Ren Ng. 2021. NeRF: representing scenes as neural radiance fields for view synthesis. Commun. ACM 65, 1 (January 2022), 99–106. https://doi.org/10.1145/3503250
[2] Bernhard Kerbl, Georgios Kopanas, Thomas Leimkuehler, and George Drettakis. 2023. 3D Gaussian Splatting for Real-Time Radiance Field Rendering. ACM Trans. Graph. 42, 4, Article 139 (August 2023), 14 pages. https://doi.org/10.1145/3592433
[3] J. Kerr, C. M. Kim, K. Goldberg, A. Kanazawa, and M. Tancik, “Lerf: Language embedded radiance fields,” in Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), October 2023, pp. 19 729–19 739.
[4] M. Qin, W. Li, J. Zhou, H. Wang, and H. Pfister, “Langsplat: 3d language gaussian splatting,” in Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), June 2024, pp. 20 051–20 060.
Supervisors:
The estimation of 6D object pose plays a critical role in applications such as robotic
manipulation, augmented reality, and computer vision. This thesis will investigate two distinct
approaches to solving the problem of 6D object pose estimation: classical computer vision
techniques and modern deep learning methods. The classical approach will leverage OpenCV
and ArUco markers for pose estimation, emphasizing foundational knowledge and traditional
methodologies. Camera calibration and marker-based detection will be implemented and
tested under varying conditions to assess their robustness and accuracy.
The second approach will explore state-of-the-art deep learning models tailored for
markerless 6D pose estimation. Following a comprehensive literature review, a state-of-theart neural network model will be selected, implemented, and trained or fine-tuned using
publicly available datasets, potentially supplemented by novel datasets collected during the
study. The study will evaluate the performance of the model in estimating the pose of
complex objects, comparing its results with the classical approach.
The final analysis highlights the strengths and limitations of both methodologies concerning
accuracy, computational complexity, and generalizability. This comparison aims to provide
insights into selecting suitable techniques for different practical scenarios and advance the
understanding of object pose estimation challenges.
The final bachelor thesis document can be downloaded here.
Short bio: Mr. Guenther Hutter will start at CPS on 1st of September in 2025.
Günther Hutter is an experienced educator and researcher in the fields of computer science, automation, and cybersecurity. He holds degrees in Software Design and Advanced Security Engineering from the University of Applied Sciences Kapfenberg, both awarded with distinction. His professional background includes leadership roles in software development and PLM integration, with a focus on software architecture, data quality, and industrial IT systems.
Since 2017, he has served as head of the IT & Smart Production division at HTL Leoben, where he is responsible for curriculum development and interdisciplinary laboratory instruction across multiple engineering domains. His teaching and research interests encompass embedded systems, industrial communication, IT security, and open-source educational technologies. As founder of bytebang e.U., he also engages in applied research and consulting in IoT, data visualization, and system integration.
Guenther Hutter, M.Sc.
Doctoral Student supervised by Univ.-Prof. Dr. Elmar Rueckert.
Montanuniversität Leoben
Roseggerstrasse 11 ,
8700 Leoben, Austria
Phone: +43 3842 402 1901
Email: TBA
Web Work: CPS-Page
Chat: WEBEX
Personal Website: bytebang.at
GitHub: bytebang
LinkedIn: Günther Hutter
[/aam]
Short bio: Mr. Sai Puneeth Reddy Gottam started at CPS on 1st of July in 2025.
He received his Master degree in Automation and Robotics from RWTH Aachen University in 2024 with the study focus on Robotics and Machine Learning. His thesis was entitled “Adaptive feature tracking in visual odometry using self-supervised learning for
challenging environments”, which took place at Space Application Services NV/SA, Brussels. In the thesis, he implemented Self-supervised learning improving feature detection for Visual Odometry in complex large scale environments. Before that, he also did his Research internship at Space Application Services, where he worked on synthetic data generation and object detection for vessel detection.
M.Sc. Sai Puneeth Reddy Gottam
Doctoral Student supervised by Univ.-Prof. Dr. Elmar Rueckert.
Montanuniversität Leoben
Roseggerstrasse 11 ,
8700 Leoben, Austria
Phone: +43 3842 402 – 1901 (Sekretariat CPS)
Email: sai.gottam@unileoben.ac.at
Web Work: CPS-Page
Chat: WEBEX
Personal Website
GitHub
Google Citations
LinkedIn
Research Gate
Supervisor: Univ.-Prof. Dr Elmar Rückert
Project:§27 Hopbas Pipe
Start date: 1st of May 2024
Theoretical difficulty: low
Practical difficulty: high
The goal of this project is to develop a webinterface to record a very large number of various sensors, to visualize the data and to store it into a database.
To connect and transform the sensor data a programmable hardware device, theAdvantech ADAM 6017-D is used.
The final bachelor thesis document can be downloaded here.
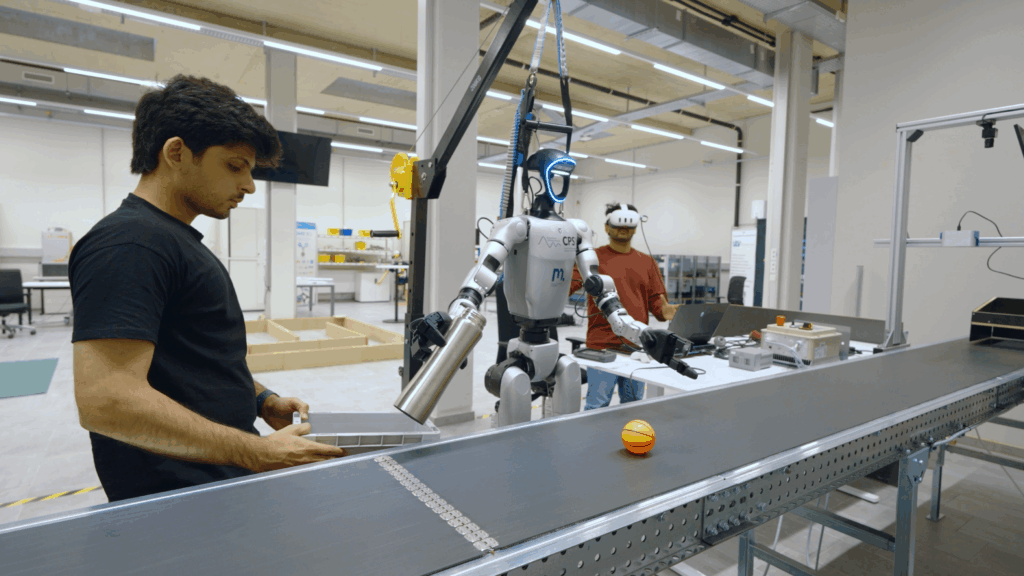
Im Labor des Hauses der Digitalisierung betreiben wir eine Kreisförderanlage zur Erforschung und zum Erlernen komplexer Robotergreifaufgaben mit KI-Methoden.
Die Anlage ermöglicht die gezielte Generierung hochwertiger Trainingsdaten unter realitätsnahen Bedingungen und bildet damit eine einzigartige Grundlage für die Entwicklung und Validierung moderner, KI-basierter Greif- und Manipulationsstrategien in industriellen Anwendungen.
So lernen beispielsweise moderne humanoide Roboter, Objekte auf Förderbändern zu erkennen, gezielt zu greifen und für Recyclingprozesse auszuschleusen.
Projektpartner:
Forschungsinnovationen sind die treibende Kraft für eine moderne nachhaltige Kreislaufwirtschaft. Um diese Innovationen zu entwickeln, haben die Lehrstühle für Cyber-Physical-Systems (CPS) und Automation und Messtechnik (A&M), ein neues Innovationsforschungslabor für Recycling (INFOR) im Haus der Digitalisierung aufgebaut.
Folgende Projektziele werden adressiert:
Kreislaufwirtschaft und Nachhaltigkeit verstehen wir als Bestandteil unsere DNA and der Montanuniversität, welche wir mit besonders innovativen multidisziplinären Ansätzen aus dem Bereich der Digitalisierung / Robotik sowie der Recyclingtechnik und der Reststoffverwertung gerecht werden. Diese Themen werde im Innovationsforschungslabor praxisnahe untersucht.
Digitalisierung ist ein Querschnittsthema welches quer über alle Schwerpunktbereiche der Montanuniversität besonders relevant ist. Auch für die Unterstützung der lokalen Industrie werden Digitalisierungsthemen an der Montanuniversität die Wettbewerbsfähigkeit der nationalen Industriebetriebe stärken, beispielsweise durch Nutzung von neuen Technologien die an der Montanuniversität erforscht werden, oder durch direkt zielgerichtete Unterstützung in kooperativen Projekten und Kooperationen.
Die Robotik ist als einer der zentralen Megatrends sowohl in Industrie als auch im Consumer-Bereich. Humanoide Roboter sind beispielsweise als neue Technologie in den Startlöchern, mit bereits sichtbarem exponentiellem Wachstum und beeindruckenden Prognosen, z.b., laut der Bank of Amerika sollen die globalen Verkaufszahlen von Humanoiden Robotern im Jahr 2030 bei 1 Million Einheiten liegen, und prädiziert wird für 2060 die beeindruckende Anzahl von 3 Milliarden humanoiden Robotern.
Im Bereich des Recycling werden neue Konzepte durch robotische Lösungen, aber auch durch den Einsatz von Sensorik und Maschinellem Lernen, insbesondere aber durch die Kombination der genannten Disziplinen in multidisziplinären gemeinsamen Arbeiten untersucht und entwickelt.
Zentrale Forschungsfragen welche direkt die Kompetenzen und Forschungsbereiche der beiden beteiligten Lehrstühle betreffen:
Das Innovationsforschungslabor für Recycling bietet die Möglichkeit, komplexe Aufgabenstellungen und Fragestellungen unter realitätsnahen Bedingungen zu untersuchen. Es erlaubt die autonome und semi-autonome Erfassung großer Datenmengen und dient als Testumgebung für innovative Sensor- und Greiftechnologien.
Ein besonderer Schwerpunkt liegt auf der Zusammenarbeit mit Industriepartnern zur Erprobung humanoider Roboter im industriellen Umfeld.
Aktuell wird das Labor in folgenden Industriekooperation genützen: