








News
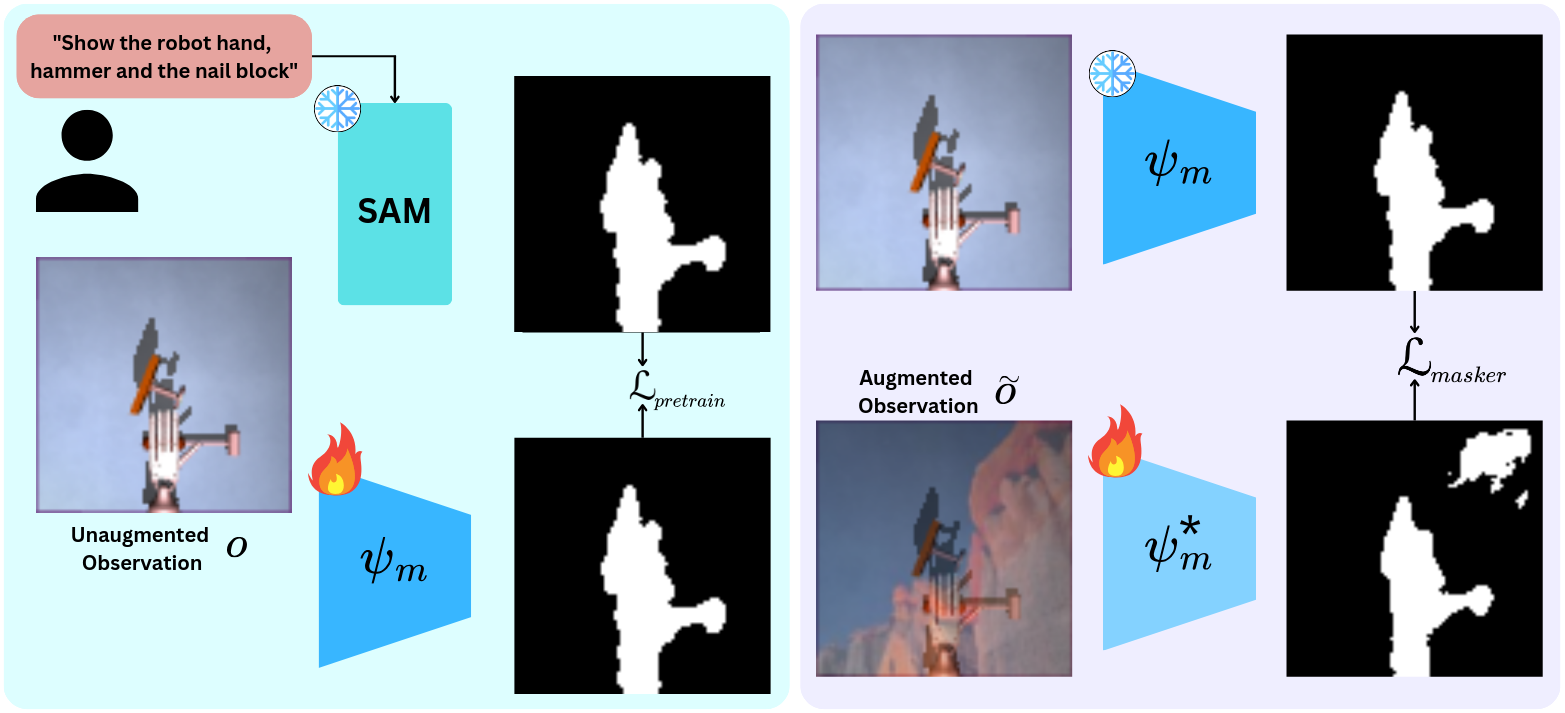
Our paper by Vedant Dave, Christian Rauch and Elmar Rueckert on “Task-Relevant Language-conditioned Segmentation for Robust Generalization in Reinforcement Learning” was accepted for publication at the Transactions on Machine Learning Research (TMLR) in July 2026.
We are pleased to announce that our EU-funded Doctoral Network project has been successfully approved. The project offers an exciting opportunity for doctoral candidates to gain both academic and industrial experience, including 18 months at Siemens in Graz and 18 months at the Chair of Cyber-Physical Systems (CPS) in Leoben.…Read More
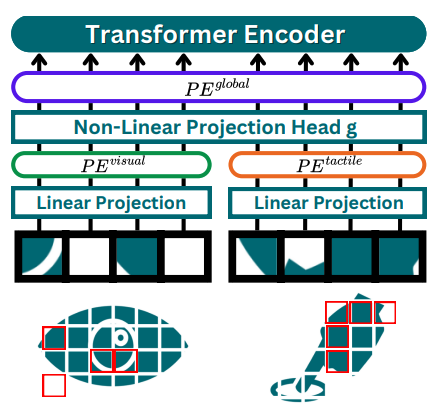
The paper by Fotios Lygerakis, Ozan Özdenizci, and Elmar Rueckert titled ‘ViTaPEs: Visuotactile Position Encodings for Cross-Modal Alignment in Multimodal Transformers’ has been accepted for publication at TMLR (Transactions on Machine Learning Research) in April 2026. The work introduces a novel approach for aligning visual and tactile information in multimodal transformer…Read More

Our proposal RoboWork—an industrial research initiative focused on advancing humanoid robotics for real-world applications—has been accepted for funding! Over the coming years, the project will drive knowledge creation, development, and evaluation of key technologies that are not yet sufficiently explored or translated into industrial-grade solutions. RoboWork aims to unlock the…Read More
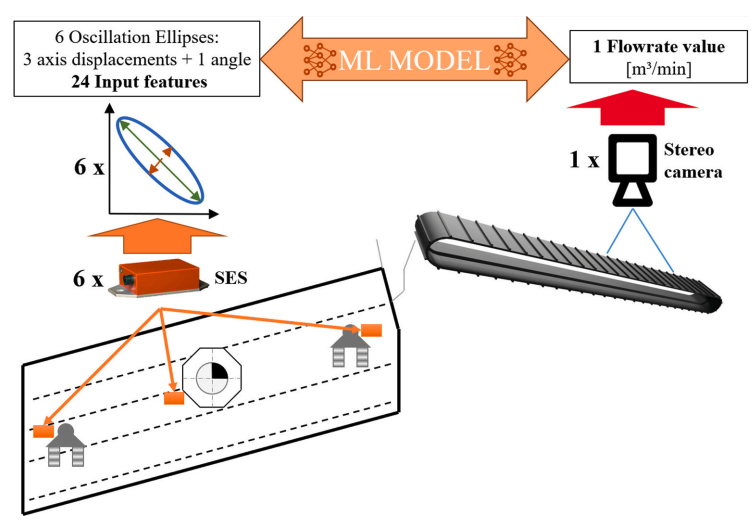
We are pleased to announce that our latest paper, ‘Prediction of feed flowrates, based on vibration patterns, generated by vibration sensors on an industrial circular vibrating screen using a set of ML models’ by Philip Krukenfellner, Elmar Rueckert and Helmut Flachberger, has been published in the journal Minerals Engineering (Impact Factor 5.0…Read More
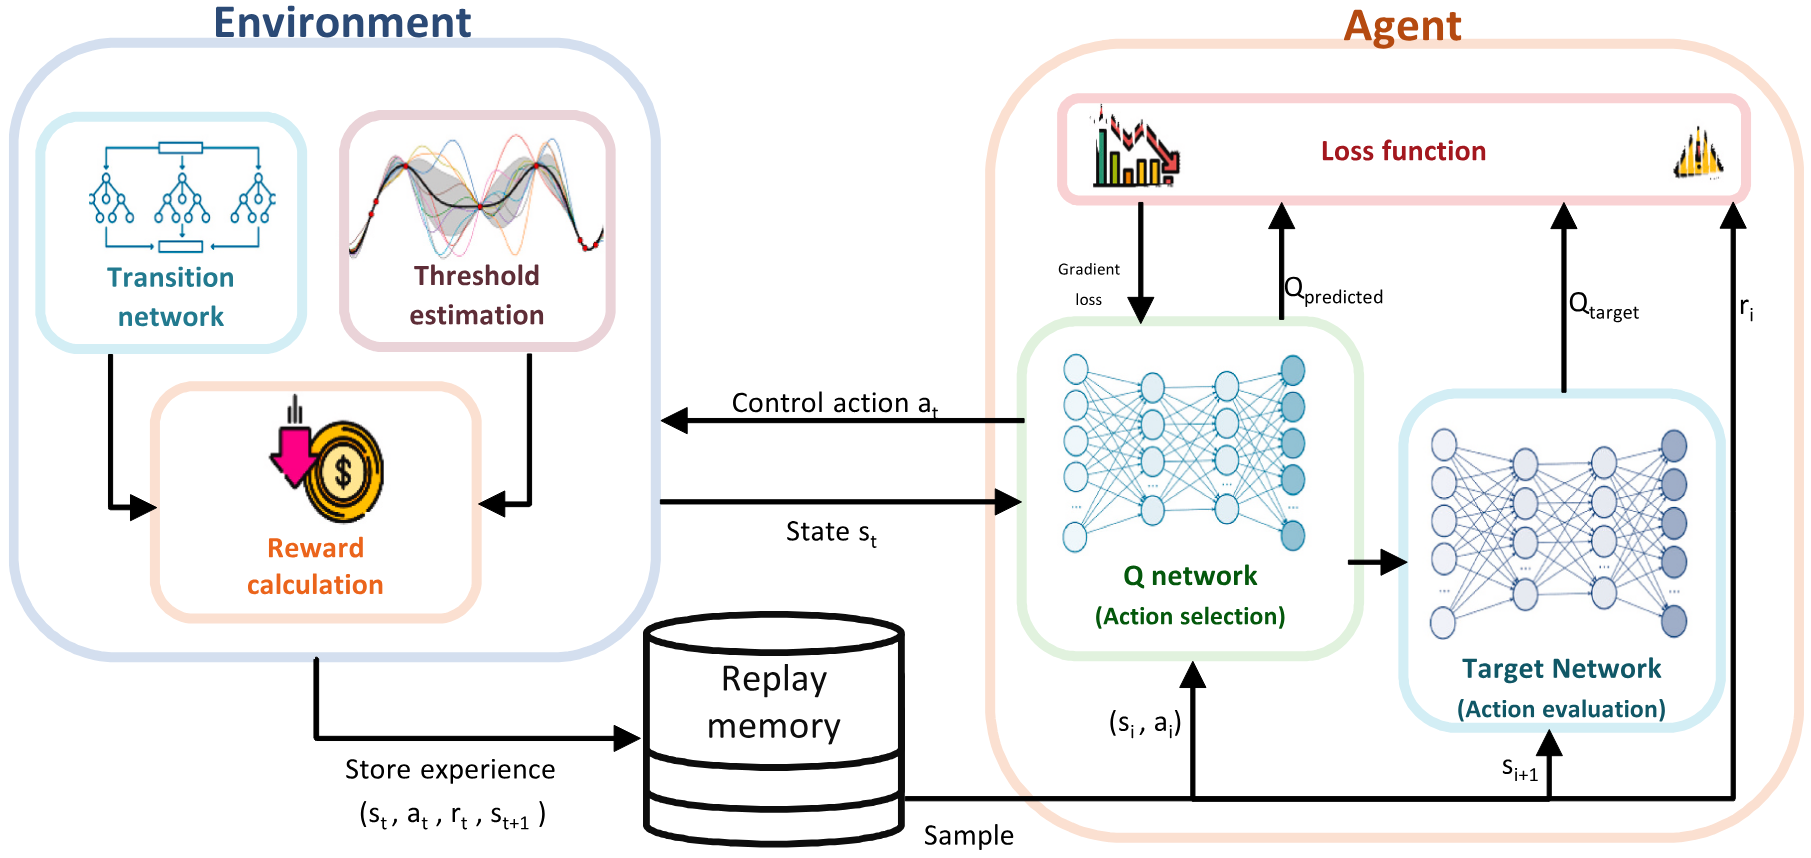
We are pleased to announce that our latest paper, “Deep reinforcement learning for automated decision-making in wellbore construction”, by Sahar Keshavarz , Asad Elmgerbi , Vedant Dave, Elmar Rückert, and Gerhard Thonhauser, has been published in the journal Energy Reports (Impact Factor 5.1 2025).
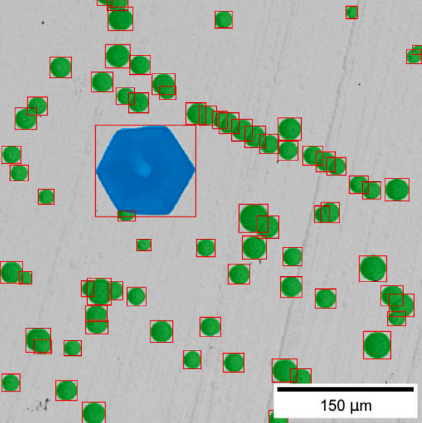
We are pleased to announce that our latest paper, “Instance segmentation pipeline for etch pit detection and prismatic slip characterization on silicon carbide substrates”, by Georg Holub, Sebastian Hofer, Thomas Obermüller, Elmar Rückert, and Lorenz Romaner, has been published in the journal Engineering Applications of Artificial Intelligence (Impact Factor 8.0,…Read More
Our paper by Vedant Dave, Ozan Özdenizci and Elmar Rueckert on “Learning Robust Representations for Visual Reinforcement Learning via Task-Relevant Mask Sampling” was accepted for publication at the Transactions on Machine Learning Research (TMLR) in August 2025.
Our paper by Marko Jamsek, Elmar Rueckert and Jan Babic on ‘Foot Placement Prediction in Real-Time Using Probabilistic Movement Primitives’ was accepted at the IEEE-RAS International Conference on Humanoid Robots 2025.
Our proposal MINEView—an initiative focused on autonomous systems for assessing underground mining conditions and delivering early warnings—has been accepted for funding! Over the next three years, the CPS team will develop cutting-edge technologies for autonomous navigation, SLAM, condition monitoring, inspection, and AI-based inference in challenging underground environments.
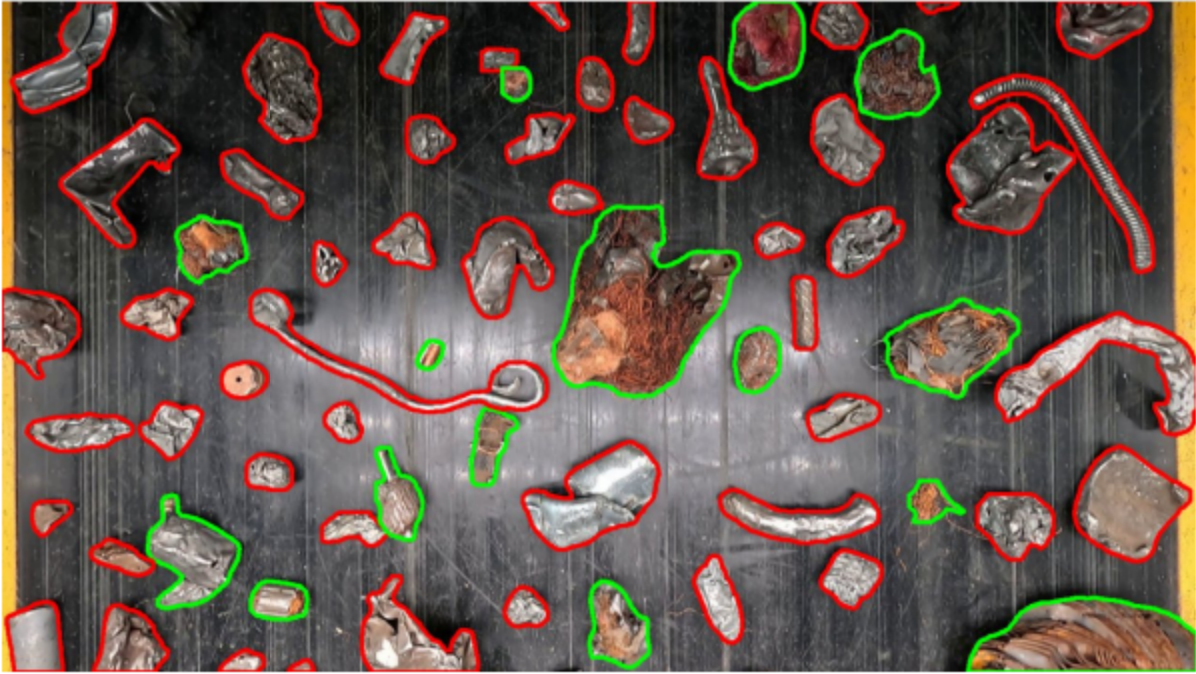
The paper by Melanie Neubauer and Ozan Özdenizci and Justus Piater and Elmar Rueckert on Sparsifying instance segmentation models for efficient vision-based industrial recycling was selected for publication at the European Conference on Machine Learning and Principles and Practice of Knowledge Discovery in Databases (ECML 2025).
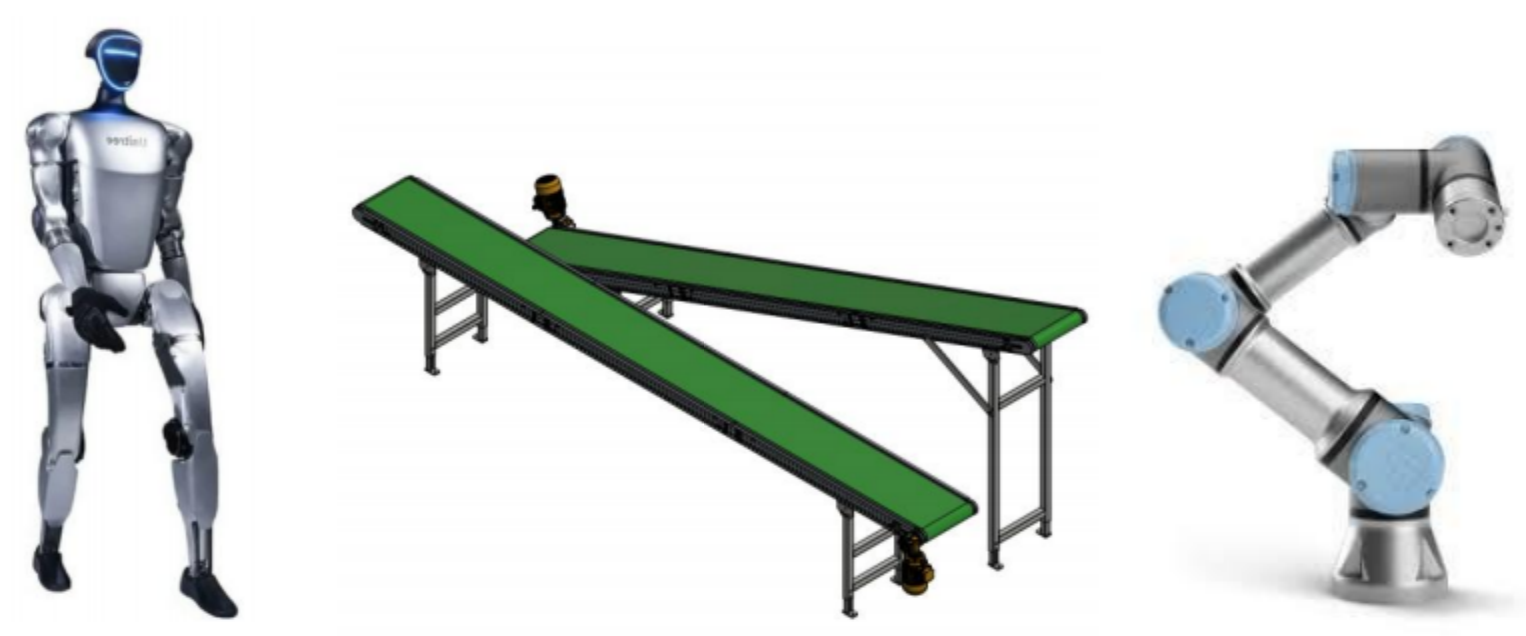
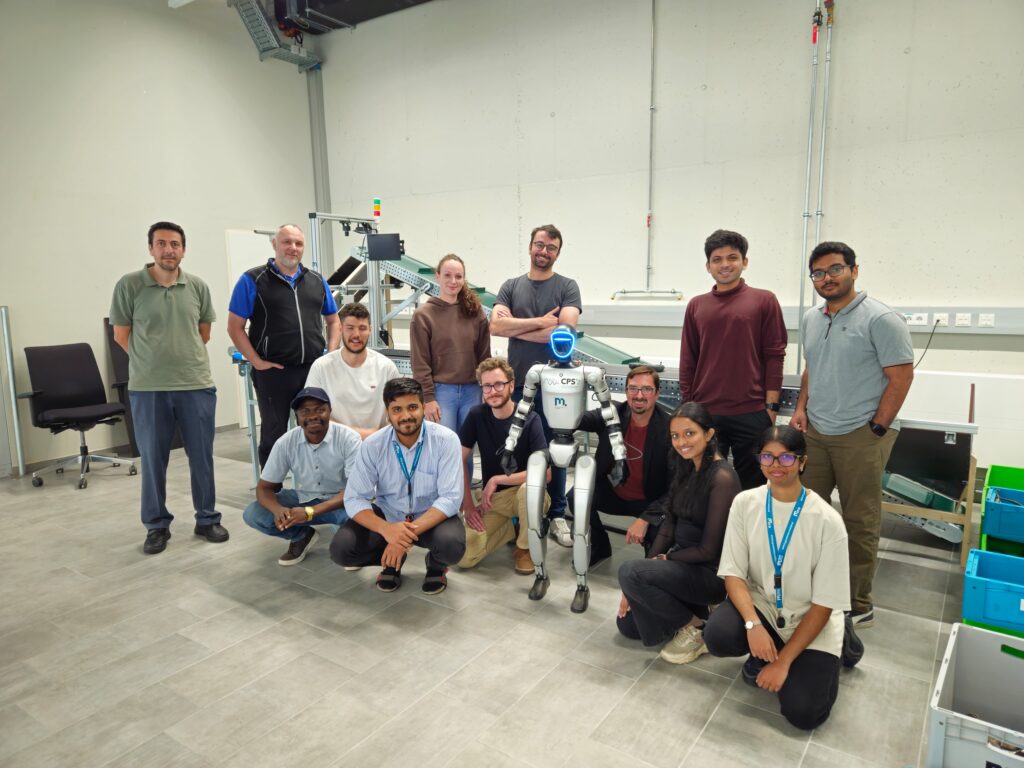
Our joint grant proposal with Prof. Thomas Thurner was selected for funding by our university rectorate. We will set up an Innovation lab for automation, robotics, and AI with a humanoid robot – a Unitree G1 with 43 DoF, 45kg, 1.2m height a circular conveyor system from Gesa – 5m…Read More
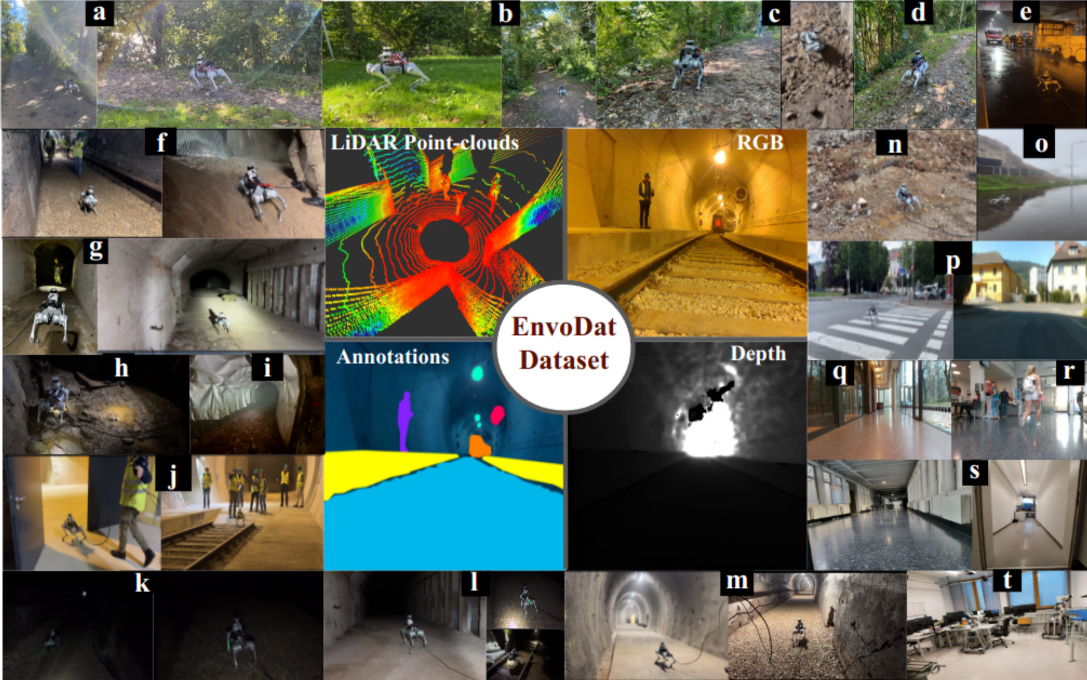
Our paper by Linus Ebere Nwankwo, Björn Ellensohn, Vedant Dave, Peter Hofer, Jan Forstner, Marlene Villneuve, Robert Galler, and Elmar Rueckert on ‘EnvoDat: A Large-Scale Multisensory Dataset for Robotic Spatial Awareness and Semantic Reasoning in Heterogeneous Environments’ was accepted for publication at the IEEE International Conference on Robotics and Automation…Read More
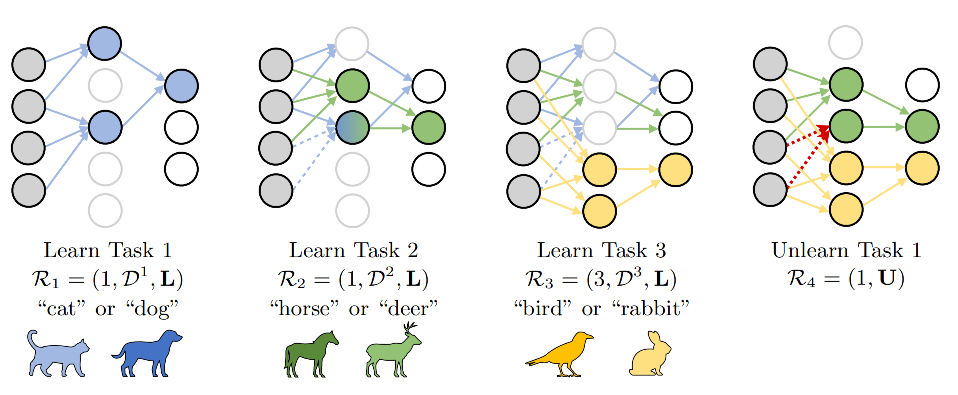
Our paper by Ozan Özdenizci, Elmar Rueckert and Robert Legenstein on ‘Privacy-Aware Lifelong Learning’ was accepted for publication at the International Conference on Learning Representations (ICLR 2025).
Our proposal, “Multi-modal, tactile-visual robotic gripping system for industrial applications” (German: “Multi-modale, taktile-visuelle Robotergreifsysteme für industrielle Anwendungen”), has been accepted for funding! Over the next three years, CPS will receive approximately half a million euros to develop cutting-edge robotic manipulation and grasping solutions, advancing innovation in industrial applications.
More news on Professor Rueckert’s page.